Robomaster - Engineer Robot
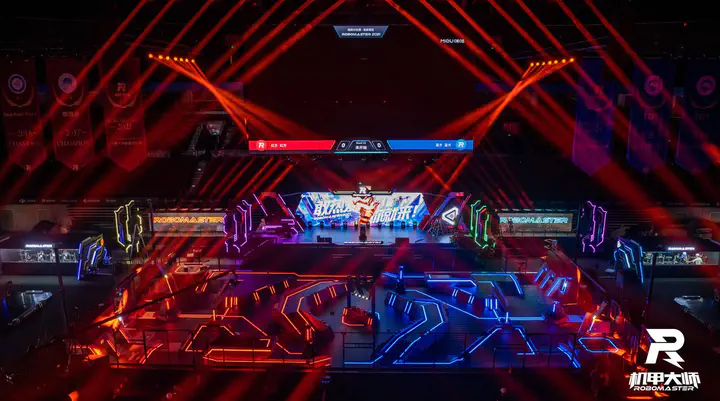
I am a member of engineering embedded software in the 21st season of Scut Robot Lab, responsible for engineering robot hardware deployment and embedded software research and development.
👉 Github: https://github.com/BenjaminChen1024/21_Engineer_Top
Engineer Robot
Engineer robot is responsible for competing for its own resources and resurrecting its own robot, which consists of two parts: mobile chassis and upper mechanism. The mobile chassis includes the McNamham wheel, the rescue mechanism and the card swiping mechanism which can move in all directions. The upper mechanism includes lifting mechanism, extending mechanism, flipping mechanism and clamping mechanism.
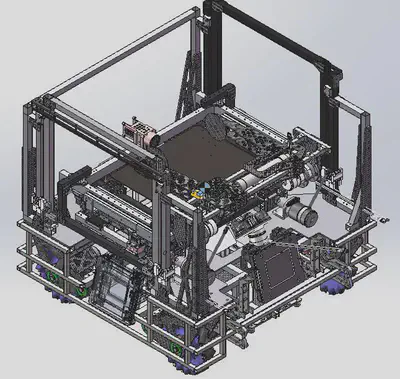
Hardware
Engineer robot hardware uses STM32F405 chip as the controller. Robomaster M3508 motor and 2006 motor are used as drivers. CAN communication protocol and serial communication protocol are adopted. Photoelectric gate and visual camera are used as sensors.
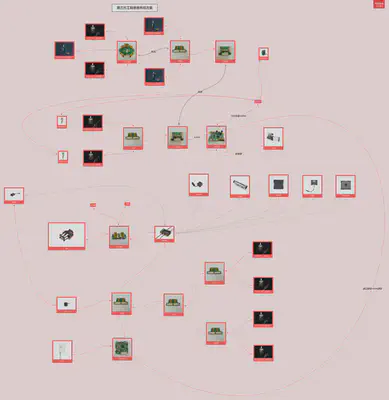
PCB Development
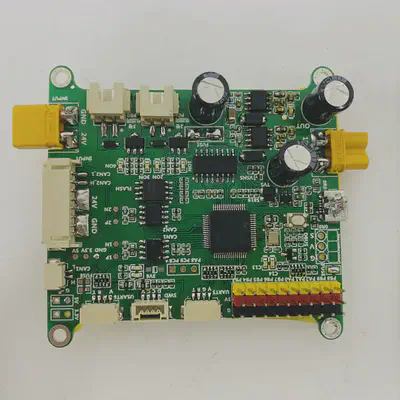
Engineer robot PCB has Chassis and Topper, which are responsible for controlling Chassis and Topper hardware devices respectively.
Chassis PCB consists of STM32F405 chip, IMU chip, CAN communication module, serial port communication module, IIC communication module, and DBUS communication module.
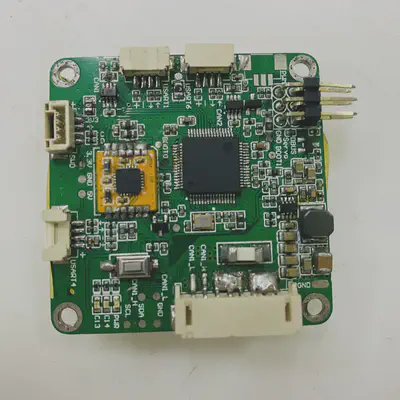
Topper PCB is composed of STM32F405 chip, CAN communication module, serial communication module, IIC communication module, free IO port, overcurrent protection module and relay module.
Softwork
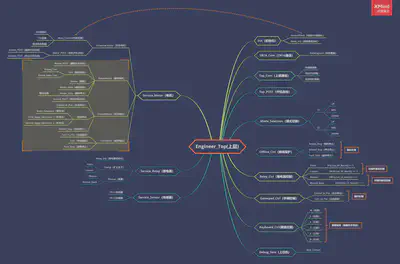
Engineer robot software is based on FreeRTOS real-time operating system, and the different modules of the robot are controlled by multi-thread management. These include motor control, visual assistance, mode switching, drop protection, handle key control and so on.
Robot Control
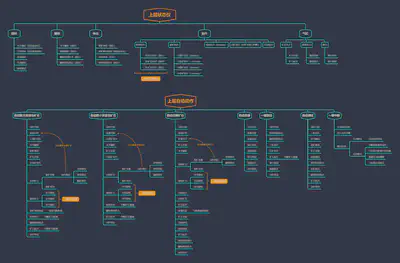
Engineer robot control is divided into action group and automatic group. The action group is assigned by the state machine to execute individual actions, including rotation, flip, extension, lift, cylinder control. The automatic group is to control the state machine through continuous instructions to execute corresponding continuous actions, including one-key mining, one-key exchange, one-key reset, automatic rescue, one-key interrupt protection.
Debug
In order to make the movement of the robot more stable and prevent various accidents in the competition, we need to debug the robot again and again, and record its test parameters such as: clamping success rate, exchange success rate, chassis moving speed, etc.
Competition
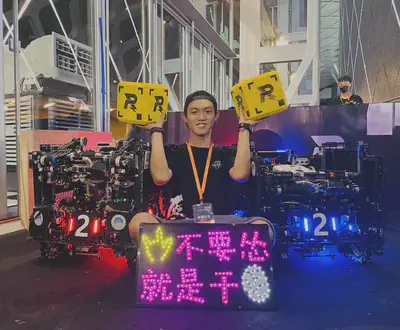
Through continuous iteration and debugging, we finally won the victory and won the first prize of the National College Student Robotics Competition RoboMaster2021 Mecha Master Competition.
Zeming Chen
Senior of Electrical Engineering
My research interests include Power Electronics, Circuit Design, Embedded Systems, and Robot Control.