Blade Wall
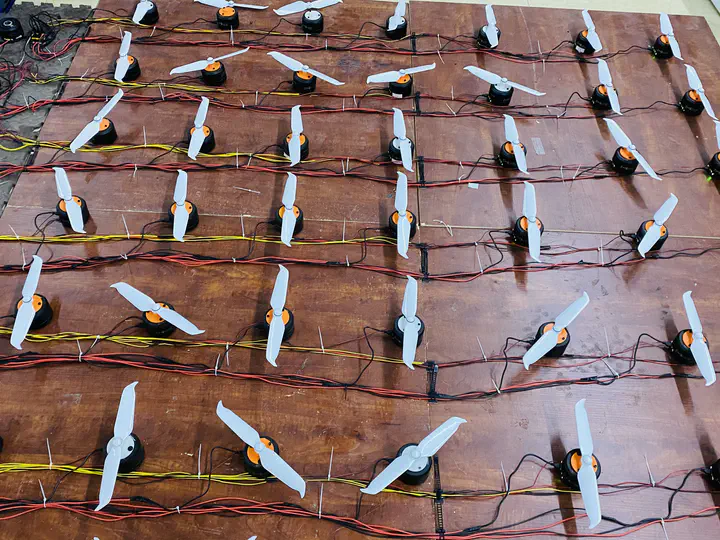
The Blade Wall is a student research and development project jointly developed by Scut Robot Lab and DJI. I am the head of the embedded system of the project, responsible for the hardware scheme and the embedded underlying firmware system of blade wall.
Blade Wall
The Blade Wall is composed of the upper computer and firmware system. The upper computer is based on Unity for body sensing monitoring and pattern algorithm implementation, while the lower computer is based on STM main control chip for motor control algorithm implementation and multi-mode underlying design.
Development
In order to make the Blade Wall more perfect, we use different algorithms for motor control, such as Kalman filter, interpolation fitting, PID controller and so on. And through a lot of debugging, we found the appropriate parameters to make the motor rotation more smooth and pattern switching more coherent.
Latest
Work continues, with the latest Blade Wall replacing the somatosensory interaction, focusing on the continuity and beauty of pattern switching.
Zeming Chen
Senior of Electrical Engineering
My research interests include Power Electronics, Circuit Design, Embedded Systems, and Robot Control.